⚙ Development Guide
> SDK
> Concept Guide
> Motion Planning Principles
PTP Point-to-Point Planning#
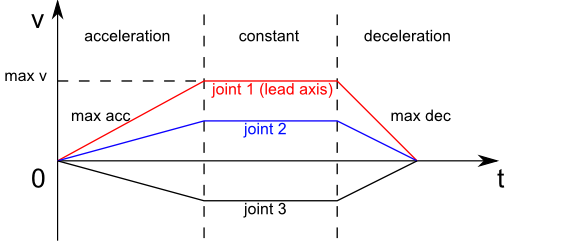
This planner generates a fully synchronized point-to-point trajectory with trapezoidal joint-velocity profiles. It assumes that all joints have the same maximum joint velocity, acceleration, and deceleration limits. If they do not, the strictest limits are used. The axis that takes the longest to reach its target is selected as the leading axis. The other axes are slowed so that they share the same acceleration, constant-velocity, and deceleration phases as the leading axis.
See the following diagram for details:
When using PTP planning, configure the following parameters in options:
motion_type: Planning type, which must be set toPTPvelocity_scaling_factor: Scaling factor for the maximum joint velocityacceleration_scaling_factor: Scaling factor for the maximum joint acceleration/decelerationsampling_time: Sampling interval (in seconds)allow_planning_time: Maximum allowed planning time