Skip to content
Technology
Foundation Model ORION
Data Engine LOOP
Simulator DISCOVERSE
Product
AIRBOT P7
AIRBOT Play
AIRBOT R1
AIRBOT E2
AIRBOT G2
AIRBOT MMK2
AIRBOT PTK2
AIRBOT TOK4
QMMK
Solution
Research & Prototype
Education & Training
Data Acquisition
Support
Documentation
Warranty & After-Sales Policy
Where to Buy
Contact Sales
About
About
Contact
EN
Buy Now
AIRBOT P7 7-Axis Robotic Arm
Robotic Arm
AIRBOT Play 6-Axis Robotic Arm
Robotic Arm
AIRBOT MMK2 Mobile Dual-Arm Platform
Integrated Platform
QMMK Quadruped Dexterous Manipulation Platform
Integrated Platform
Data Acquisition and Model Reproduction
Data and Models
No matching products
Cancel
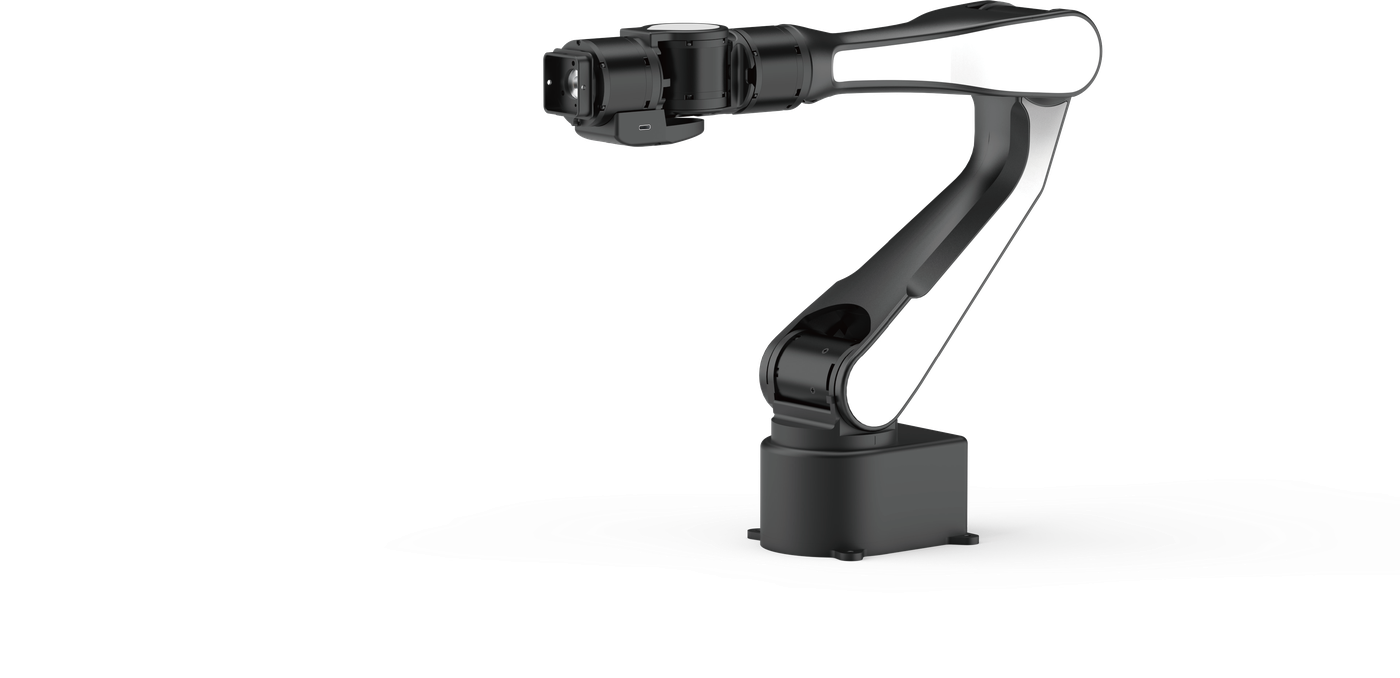
AIRBOT Play
6-Axis Robotic Arm
Enter a keyword to search this product
Product Overview
Download Center
2026.03.13
2025.06.23
2025.11.05
Documentation Reading Guide
▸ Quick Start
Product Introduction
Technical Specifications
Mechanical Structure
Hardware Interfaces
Hardware Installation
Packing List
Robot Arm Installation and Securing
End-Effector Installation [Optional Kit]
Base Connections
Basic Functions
Power-On and Power-Off
Zero Calibration
Quick Setup
Environment Preparation
Installation and Startup
Software Installation
Run the Main Program
Running Examples
List Examples
View Example Parameters
Run an Example
⚙ Development Guide
SDK
Concept Guide
SDK Introduction and Architecture
Control Authority (Lease)
Control Modes
Motion Planning Principles
PTP Point-to-Point Planning
LIN Linear Trajectory Planning
CIRC Circular Trajectory Planning
Multi-Segment Trajectory Blending
Robot Arm State and Indicator Effects
API
Data Structures
Controller
ArmControlOptions
ArmState
EEFState
CartesianPose
ServiceState
FirmwareInfo
API Reference
Examples
Appendix
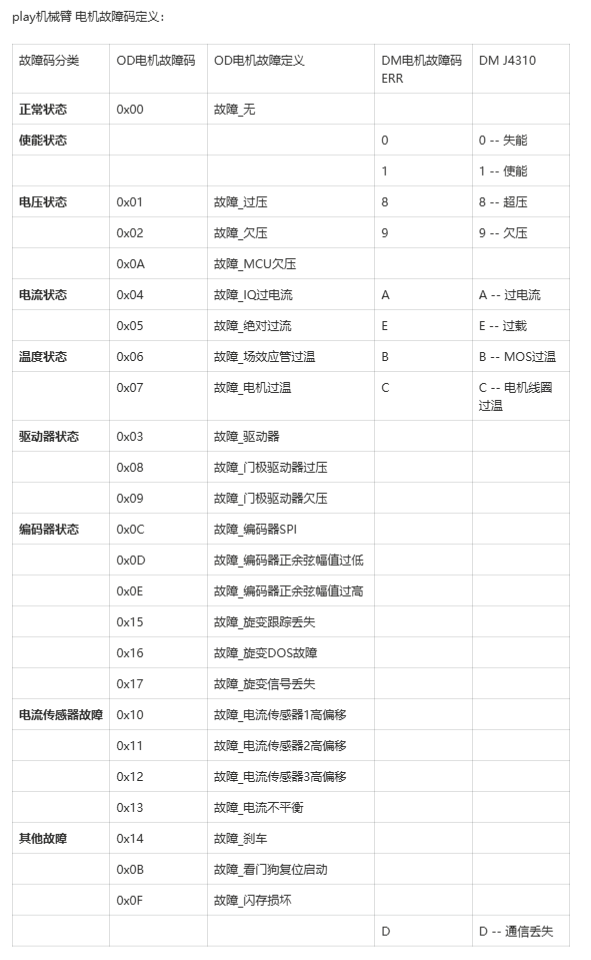
Motor Error Code Troubleshooting
Supported Teaching-Device and Gripper Models
Other Products
AIRBOT P7 7-Axis Robotic Arm
AIRBOT MMK2 Mobile Dual-Arm Platform
QMMK Quadruped Dexterous Manipulation Platform
Data Acquisition and Model Reproduction
⚙ Development Guide > SDK > Appendix
Motor Error Codes
#
Back to top