▸ Quick Start
> Quick Setup
Environment Preparation#
Confirming the Motor Versions#
The following motor hardware versions are supported:
| Motor Type | Description | Applicable Joints | Firmware Version |
|---|---|---|---|
| OD | First-generation motor developed by Airbot | Robotic arm joints 1–3 and E2 teaching device | 04114 (or later) |
| DM | Damiao motor (legacy protocol) | Robotic arm joints 4–6 and G2 gripper | 5015 |
Additional information:
- If you are currently using version 2.9, 4.x, or an earlier legacy version, upgrade the firmware first.
- If you have previously controlled the robotic arm successfully through a
hardware-version control interface, the current firmware already meets the operating requirements and can be used directly. - When using software version 5.1.6, confirm that the DM motor firmware version is
5015. Firmware information appears at the beginning of the service startup log.
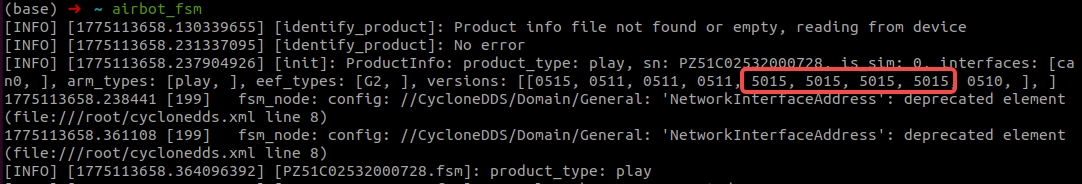
If the firmware version does not meet the requirements, contact after-sales support for the firmware-upgrade documentation.
Viewing the Robotic Arm CAN Interface#
Connect the robotic arm's USB-2 port to the computer, then enter the following command in a terminal:
First-Time Installation
-
Confirm that the
slcankernel module is loaded
Runlsmod | grep slcanto check. If it is not loaded, load the kernel module before continuing. -
Install the
can-utilstoolset
Run the following commands to make sure the system can identify CAN correctly:
Joint-Limit Values#
| Part | Degrees of Freedom | Joint Limits | Description |
|---|---|---|---|
| Robotic arm | 6 | j1: (-3.14, 2.09) | j2: (-2.96, 0.17) | j3: (-0.087, 3.14) | j4: (-3.01, 3.01) | j5: (-1.76, 1.76) | j6: (-3.01, 3.01) |
These differ from the robotic arm's actual physical limits; the safe limits in the URDF are used. |
| Gripper (G2) | 1 | GRIPPER_MIN = 0.0GRIPPER_MAX = 0.072 |
0.0 — fully closed0.072 — fully open |
| Gripper (G2L) | 1 | GRIPPER_MIN = 0.0GRIPPER_MAX = 0.1 |
0.0 — fully closed0.1 — fully open |