⚙ Development Guide
> SDK
> Concept Guide
SDK Introduction and Architecture#
AIRBOT Play SDK: Users can call SDK APIs to control robotic arm motion and obtain its state, then build their own software functionality on this foundation.
Overall Architecture#
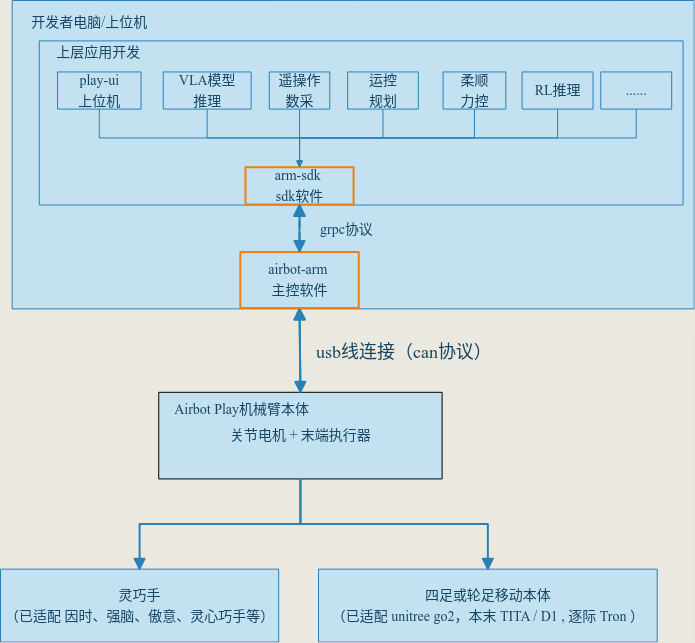
The following diagram shows the system components of and interaction between the developer computer and the Airbot Play robotic arm:
-
The developer computer and robotic arm are connected by a USB Type-C data cable.
-
The developer computer starts the robotic arm through the airbot-arm software package, then uses the APIs provided by the upper-layer sdk-client to control the arm in a variety of applications.