Running the Main Program#
Note: After powering on the robotic arm, make sure the base light bar is pulsing white. Connect the robotic arm's USB-2 interface to the computer and confirm that the system has detected the CAN interface. After completing these steps, you can control the robotic arm through the SDK.
After installing the main-program .deb package, run the following command in a terminal to start the robotic arm control service:
Note: This command must be run with sudo privileges!!!
The following arm_type parameters are currently supported:
| Parameter | Corresponding Hardware | Notes |
|---|---|---|
airbot_play |
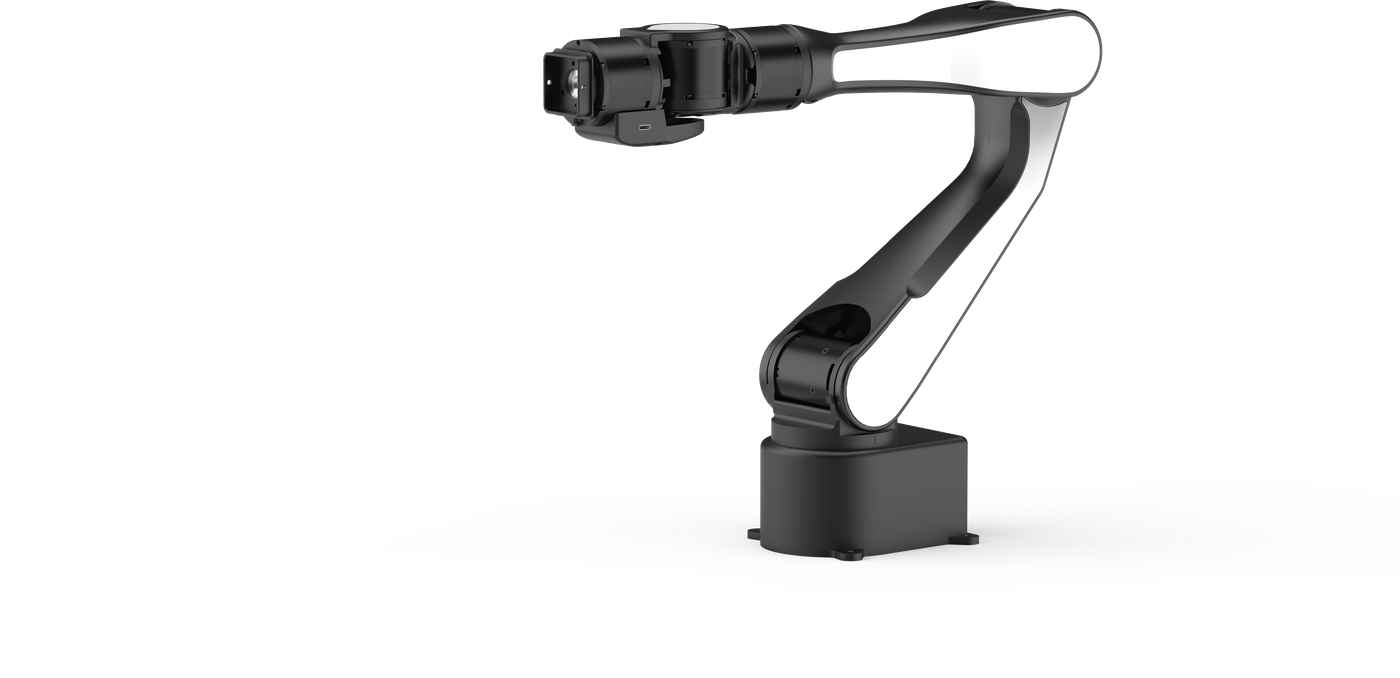
Airbot Play 6-axis robotic arm | |
airbot_play_g2 |
Airbot Play 6-axis robotic arm + G2 gripper | |
airbot_play_g2l |
Airbot Play 6-axis robotic arm + G2L gripper | |
airbot_play_e2 |
Airbot Play 6-axis robotic arm + E2 teaching device | Gravity-compensation mode only |
airbot_play_g2_d405 |
Airbot Play 6-axis robotic arm + G2 gripper + Intel Realsense D405 camera | |
airbot_play_g2l_d405 |
Airbot Play 6-axis robotic arm + G2L gripper + Intel Realsense D405 camera | |
airbot_replay |
Aibot Replay teaching device | No URDF provided |
airbot_replay_mini |
Aibot Replay Mini teaching device | No URDF provided |
For example, to start the control service for an Airbot Play robotic arm fitted with a G2 gripper and connected through can0, use the following command:
To start an Airbot Replay Mini connected through can1, use the following command:
To specify the gRPC listening Port, add the --address parameter:
To prevent the robotic arm from returning to zero when the service exits, add the --no-return parameter:
Note: If the device disconnects while the program is running, the gRPC server may be unable to exit normally. If this occurs, close the service program's terminal directly to avoid leaving the listening interface occupied.