
AIRBOT G2P Gripper#
Document status
This page comes from the draft user manual. The technical specifications still await final confirmation, and the mechanical-dimension drawings and interface photographs are marked for replacement in the original draft. The values below are retained from the draft. Use confirmed product information for final selection and acceptance.
Product Introduction#
AIRBOT G2P is a lightweight, long-stroke electric two-finger gripper with a 95 mm gripping stroke. Its compact profile when closed accommodates a wider range of object sizes and shapes. The finger shape provides more stable contact and grip when handling larger round objects, making it suitable for embodied-intelligence data collection, teaching and research, and robotic grasping applications.
Main Features#
-
Adaptive enveloping/parallel dual grasping modes
-
Replaceable fingertips
-
Feedforward force control
-
Quick-release structure for convenient removal
-
Touch support
-
Integrated drive
Technical Specifications#
Key technical specifications of the AIRBOT G2P gripper:
| Feature | Specification |
|---|---|
| Gripping range | 0~95mm |
| Maximum gripping force | 30N |
| Weight | 408g |
| Primary material | Aluminum alloy |
| Control protocol | CAN |
| Gripper power supply | DC24V |
| Power consumption | 36W |
| Gripper control frequency | 250Hz |
| Mounting method | Quick release |
Mechanical Structure and External Dimensions#
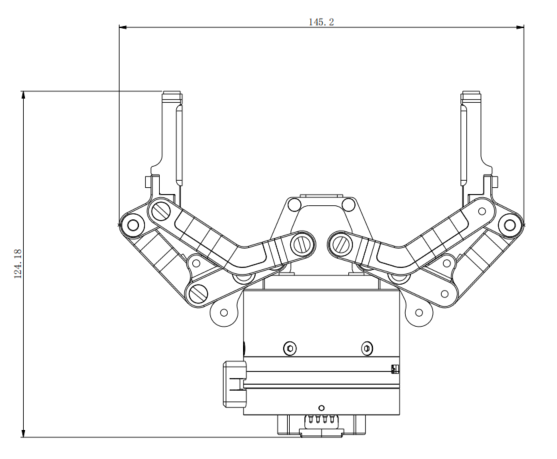
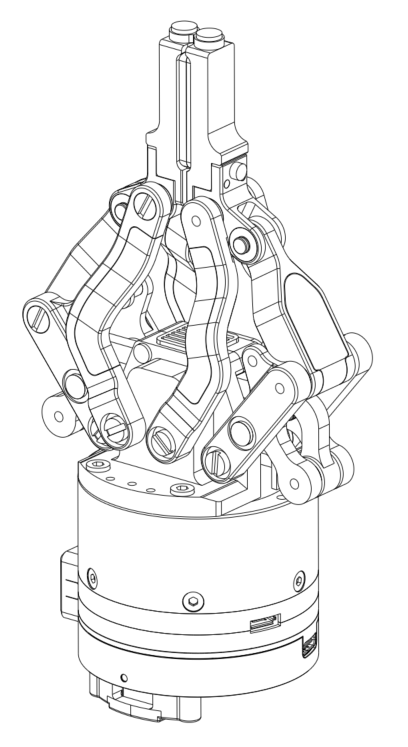
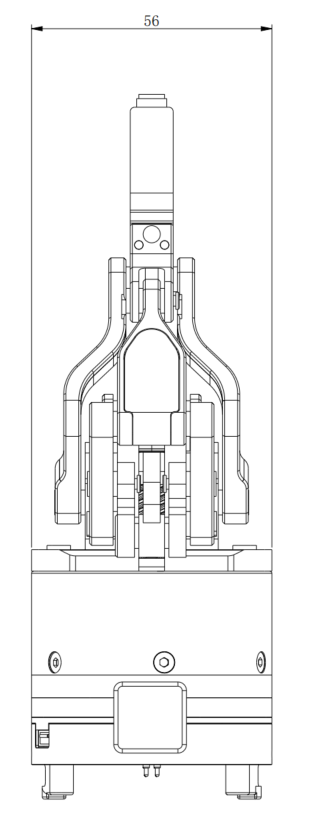
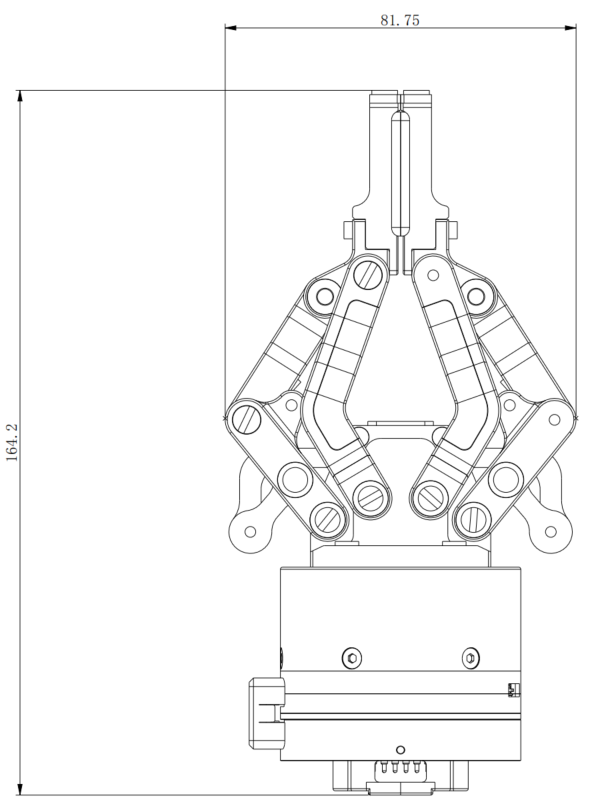
The following figures show the external dimensions of the AIRBOT G2P gripper in its open and closed states:
Hardware Interface#
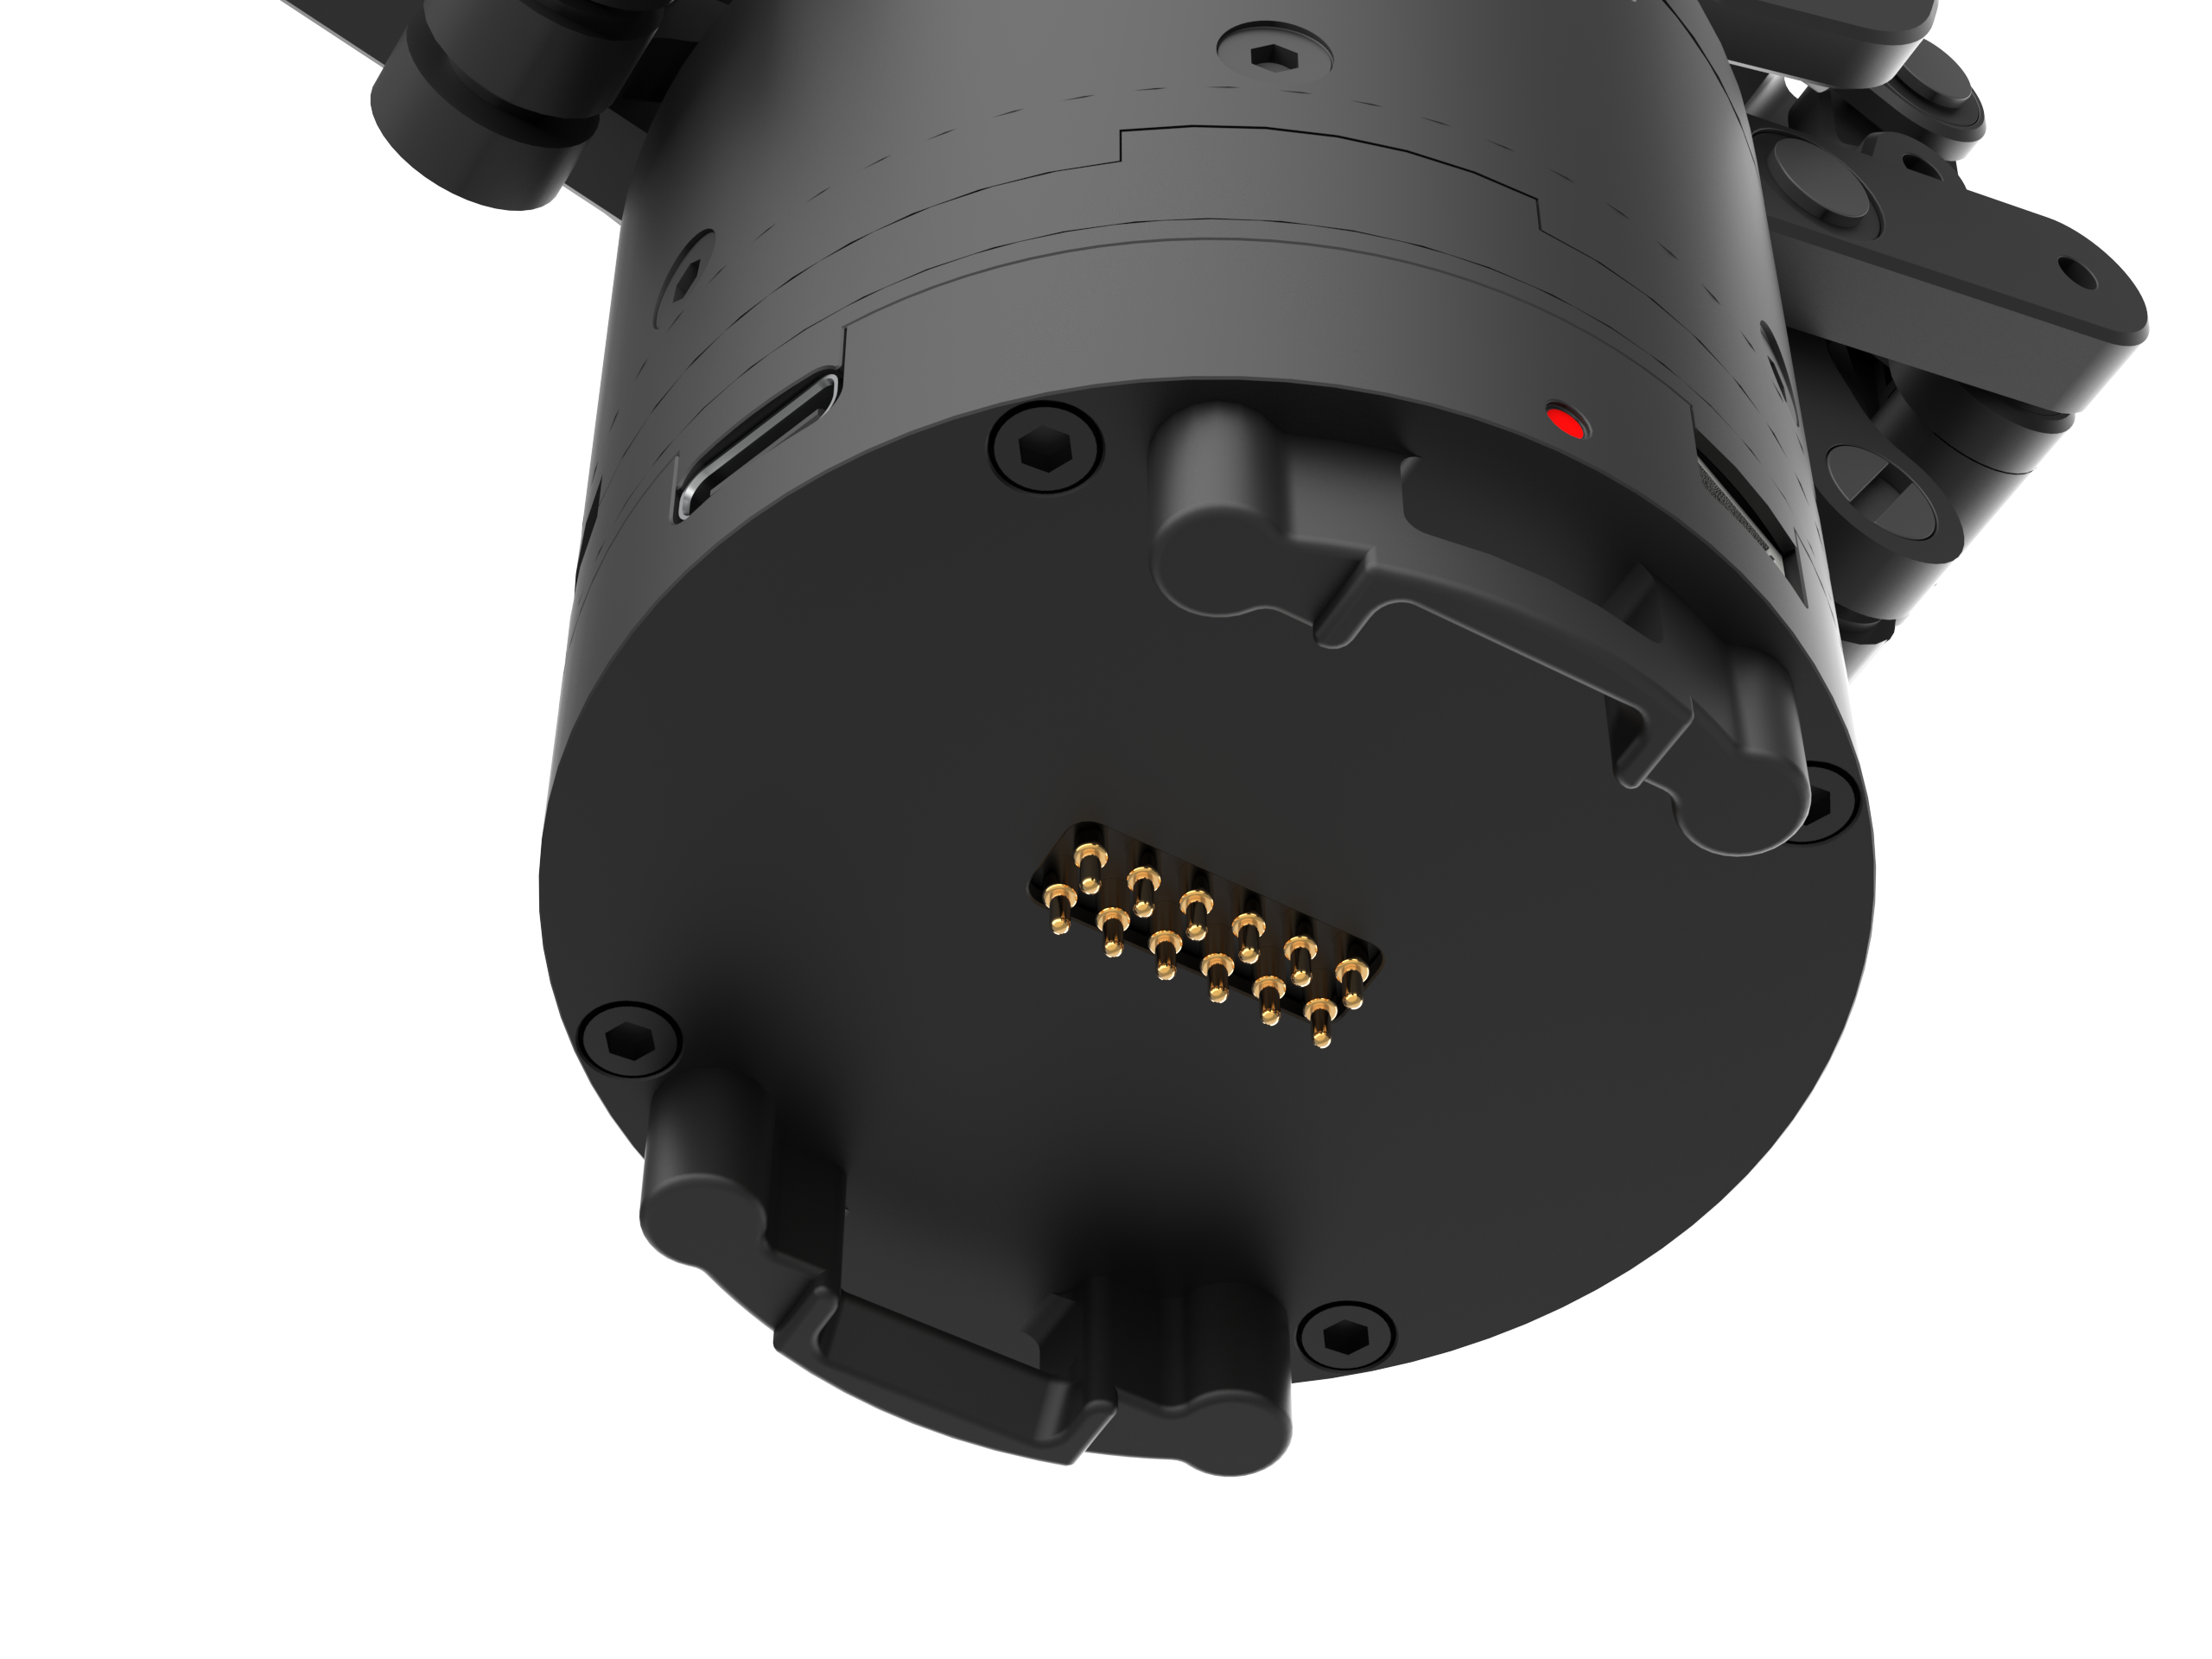
End interface: connects to the end of the robot arm through the quick-change plate's electrical contact board. Its quick-release structure keeps the appearance tidy and reduces interference from external wiring in the workspace.