List
List Examples#
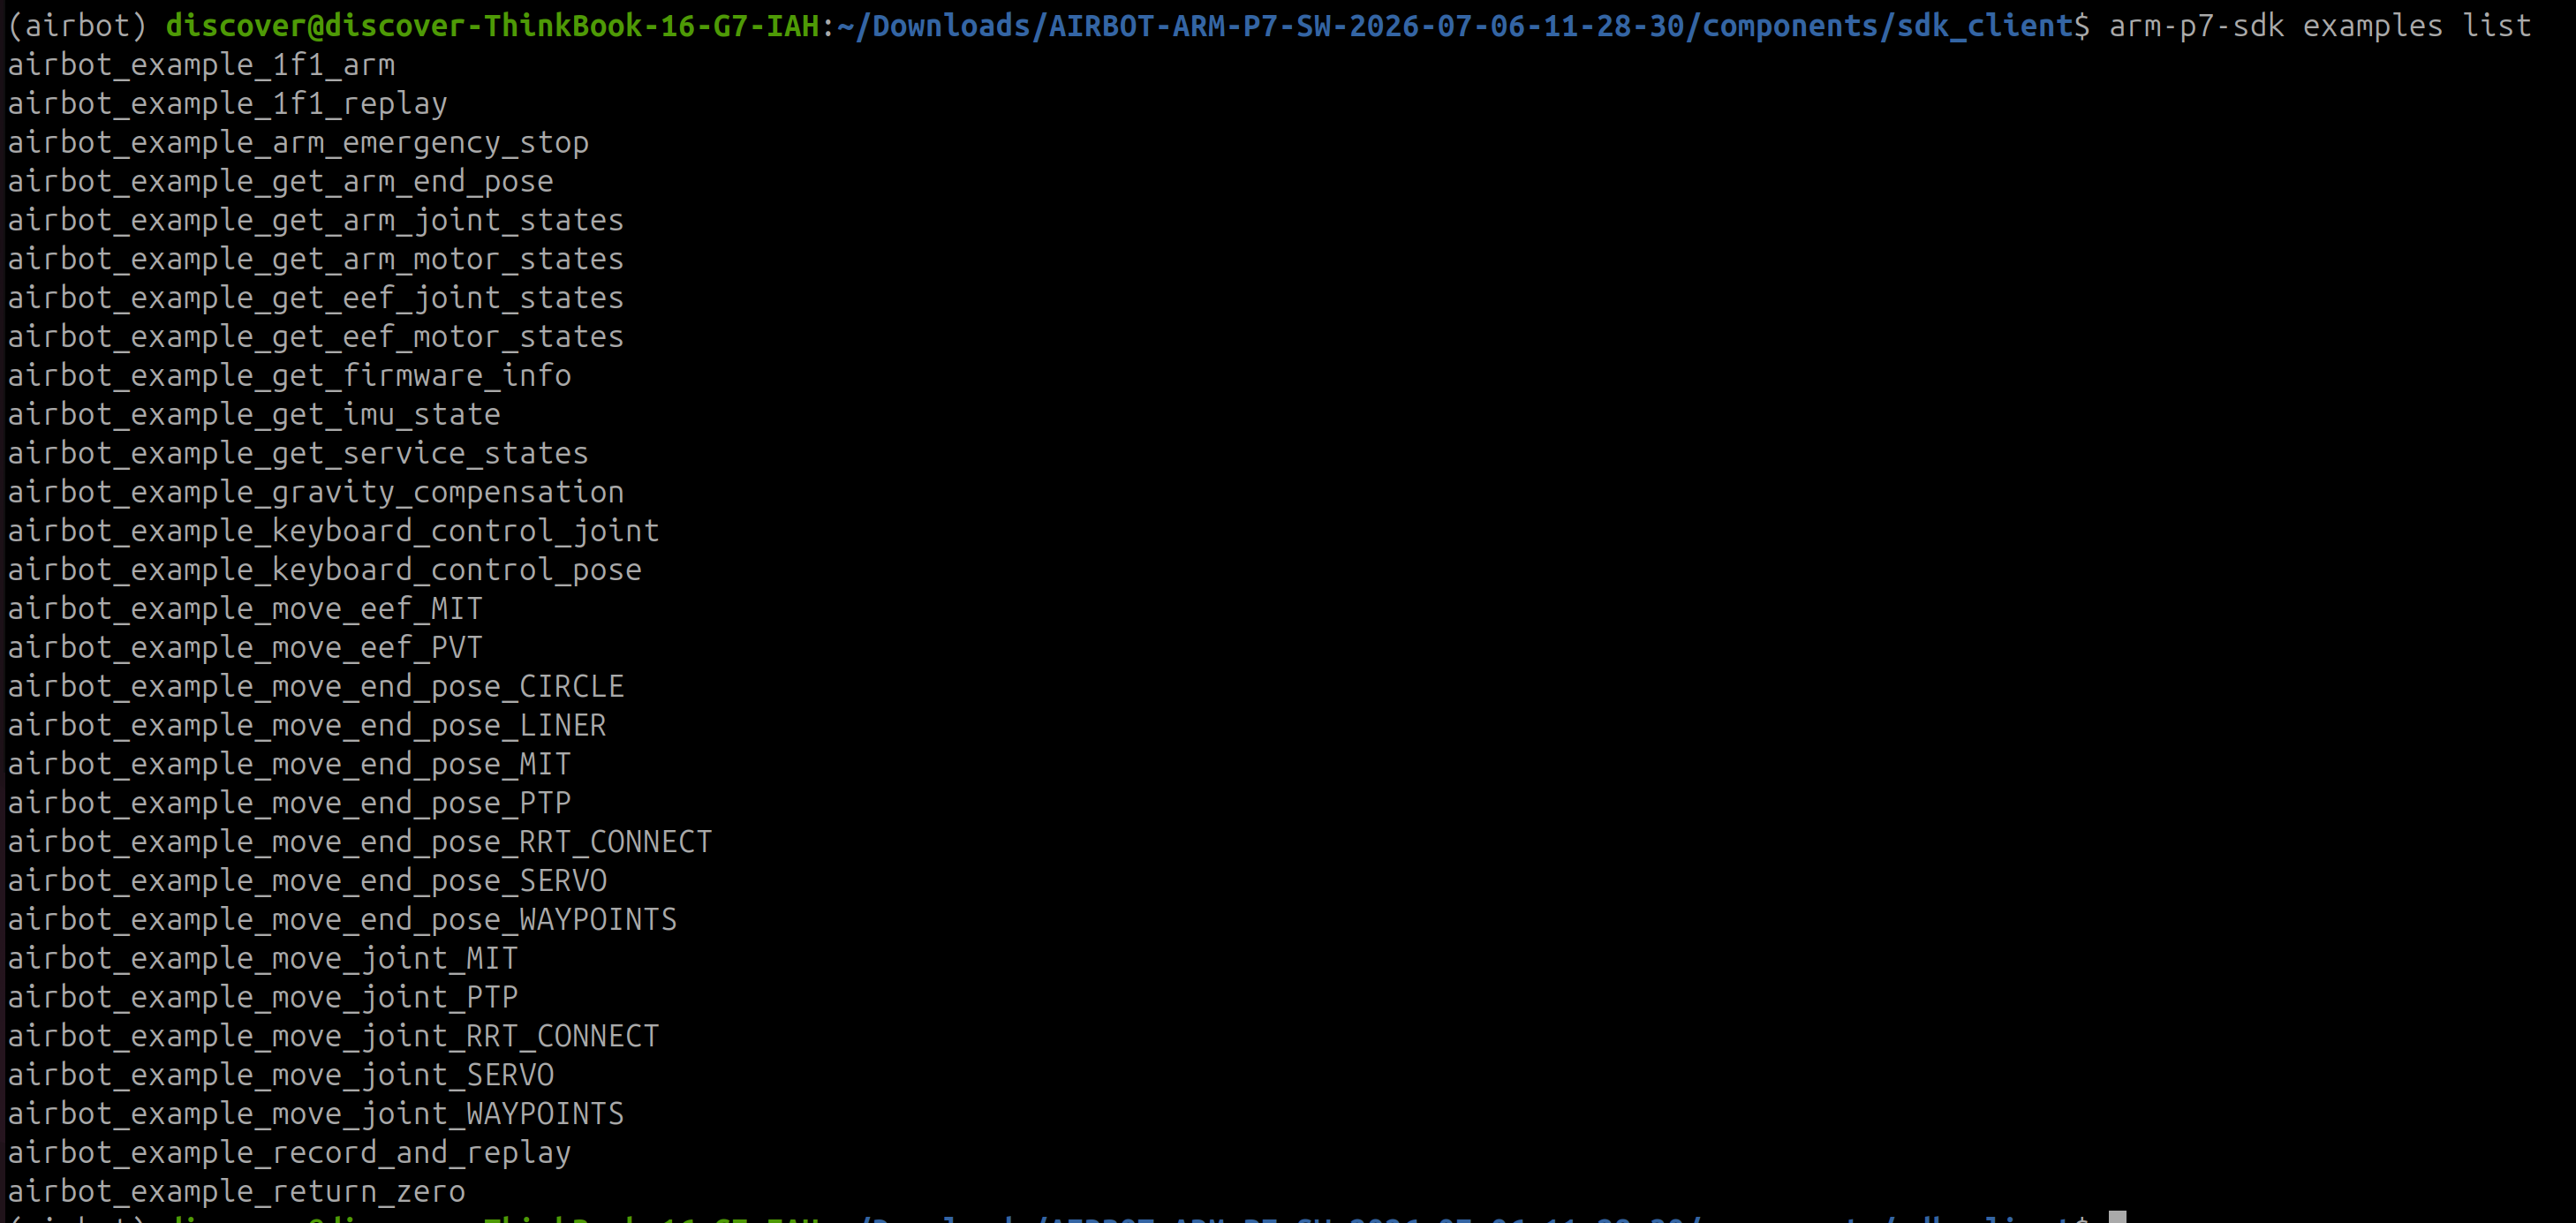
After installing the SDK wheel package, connect the robot arm to the computer through the Ethernet interface. After powering it on, enter the following command in a terminal to list the available examples: