User Information and Safety Guidelines
Robotic Arm Safety#
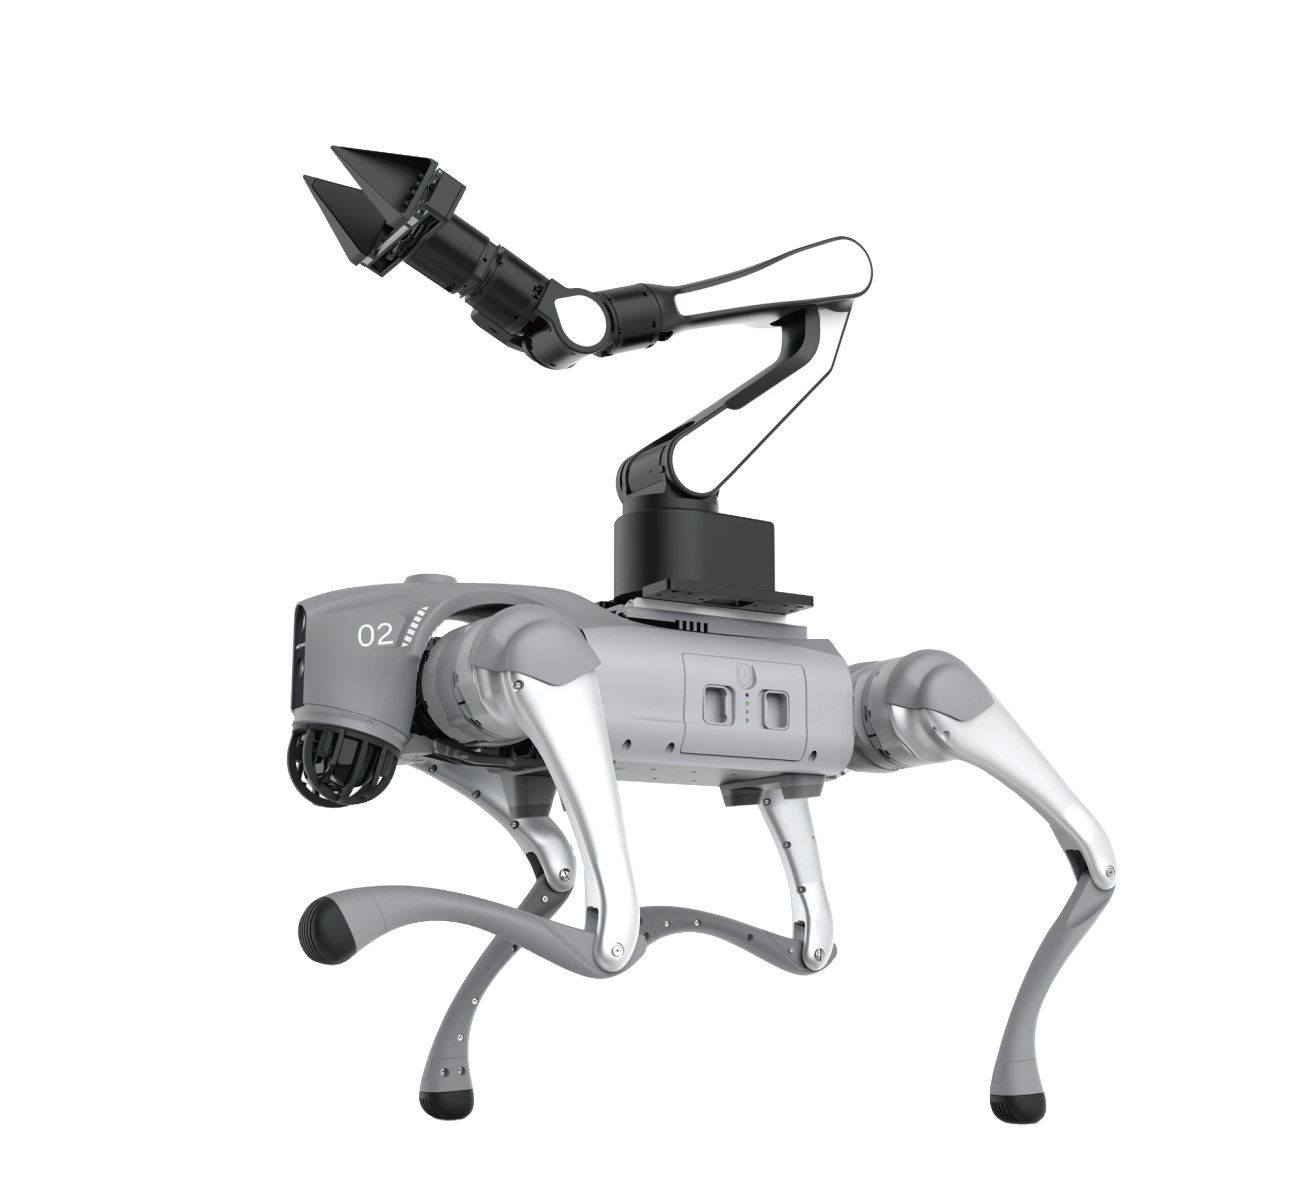
- Work-area safety: Before starting the robotic arm, you must ensure that no people or obstacles are within its workspace.
- Pre-operation inspection: Before VR teleoperation, you must confirm that all control devices, such as controllers and wrist trackers, are worn correctly and secured to prevent the robotic arm from receiving and executing incorrect control signals.
- Correct shutdown procedure: When ending teleoperation, follow the correct procedure: first release the control trigger to stop motion synchronization, and then press the zero-position button (Y on the left controller or B on the right controller) to return the robotic arm to its zero position. This sequence effectively prevents accidental movement caused by unintended input.
- Emergency response: If a control error causes the robotic arm to move out of control, immediately take either of the following emergency measures: disconnect the robotic arm's main power plug at once; or press the zero-position button (Y on the left controller or B on the right controller) to release the motor brakes.